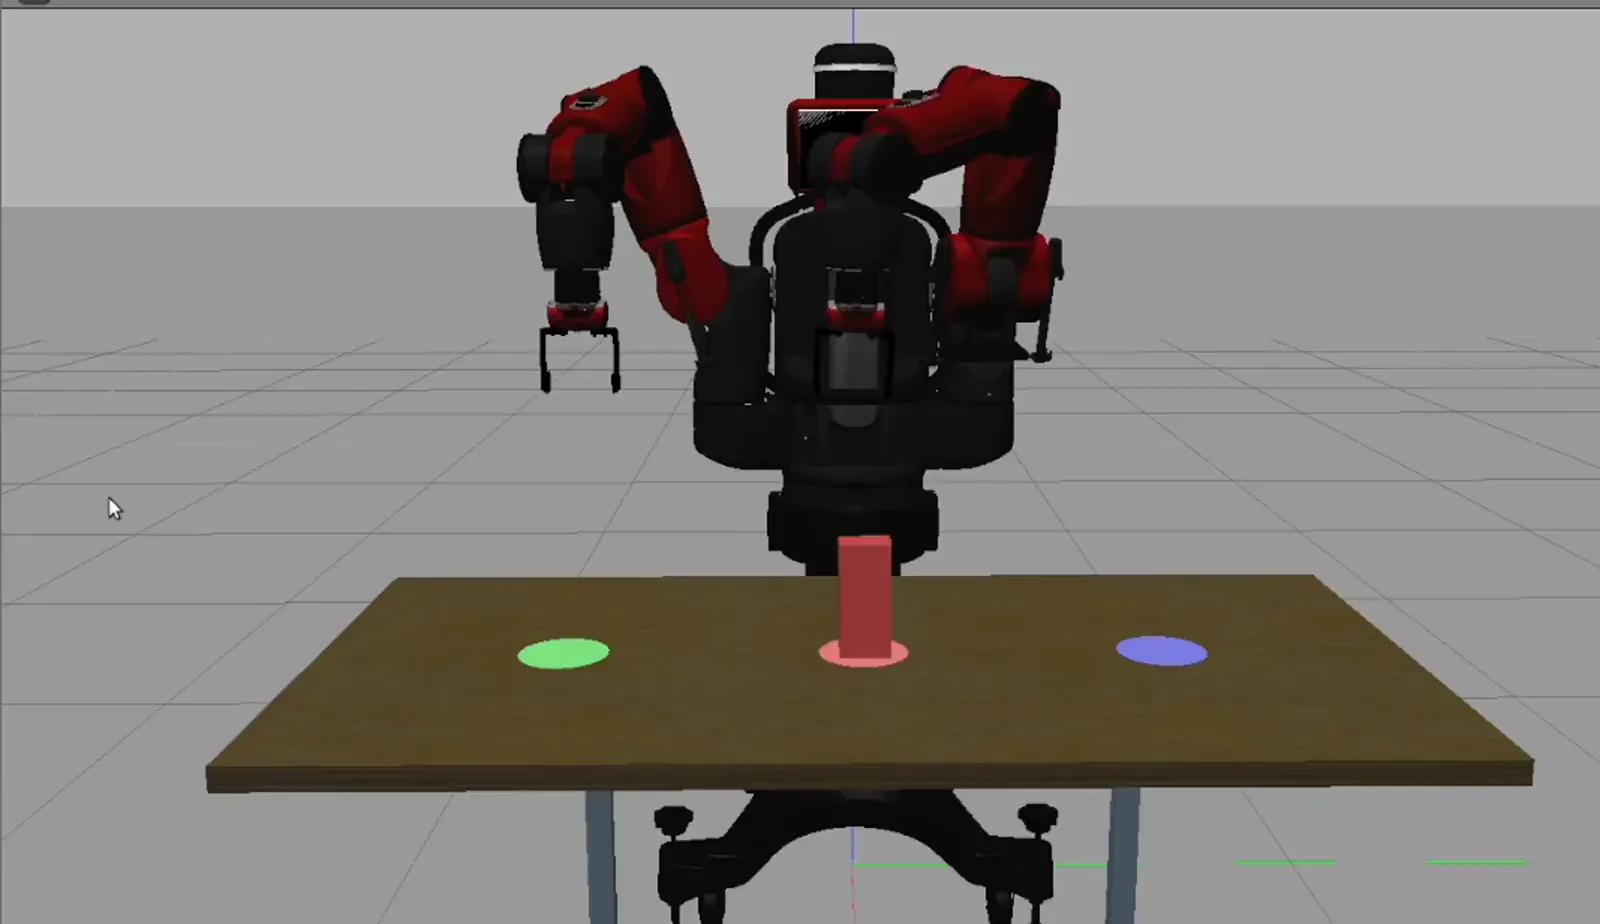
DE NIRO
Teaching a two-armed robot to plan, reach and push, in Gazebo.
Motion planning across a cluttered room with C-space dilation, potential fields and probabilistic roadmaps. Then position, velocity and torque control for pick and place, hand-overs and knocking down a wall.
Orientation set with Z-Y-X Euler angles and quaternions, so the grip arrives square.
Jacobian pseudoinverse with damped least squares, steady near singularities.
Null space projection runs a second task without disturbing the first.
Waypoints chosen so the hand-over can never collide.
- Brief
- Get DE NIRO from (0, −6) to (8, 8) m across a cluttered room, then make it pick, hand over and push.
- Role
- Simulations and code alongside the team. Co-led both reports, and a main contributor to the first interaction tasks: end-effector orientation and the hand-over.
- Outcome
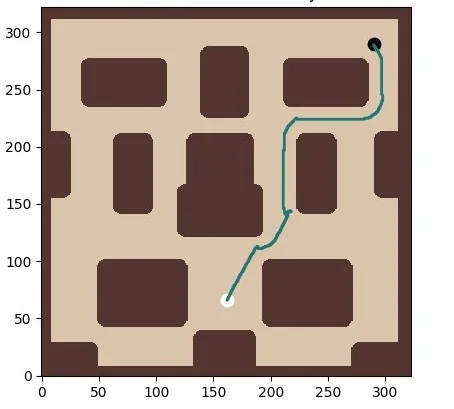
- The roadmap found an 18.05 m route against 22.0 m planned by hand, and every task was validated in Gazebo.
- 01
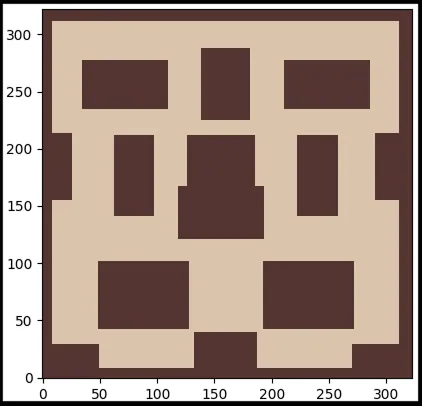
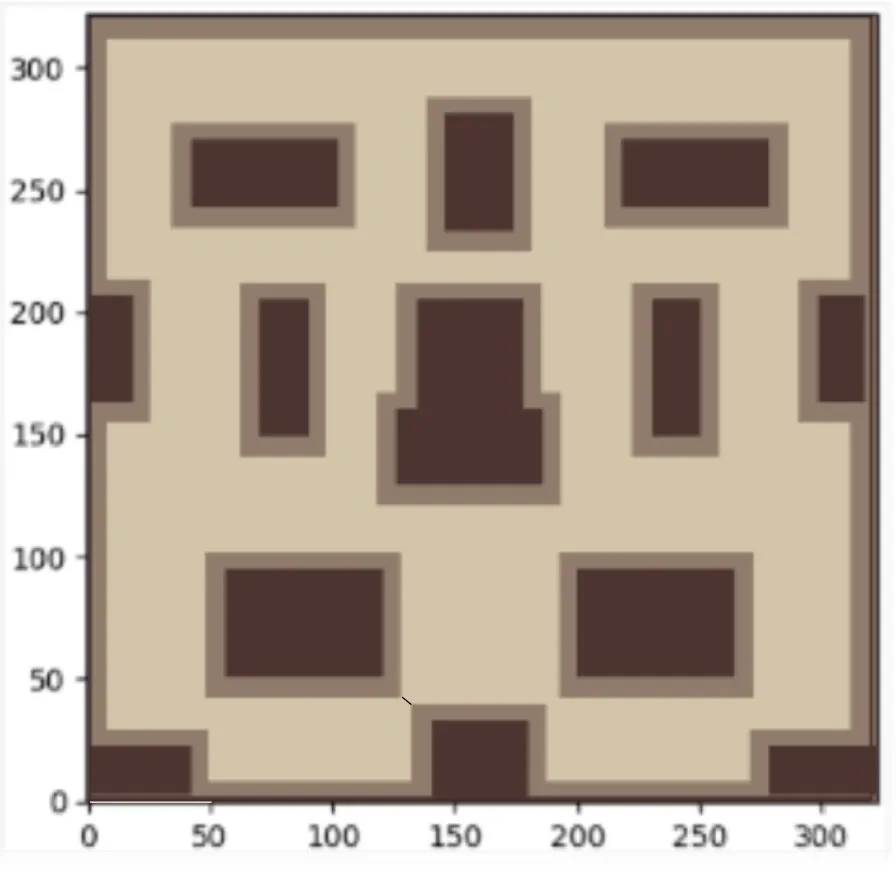
Map
The room as the robot sees it.
- 02
Dilate
Grow every obstacle by the robot's 1 m footprint. Free space shrinks by 22.8%.
- 03
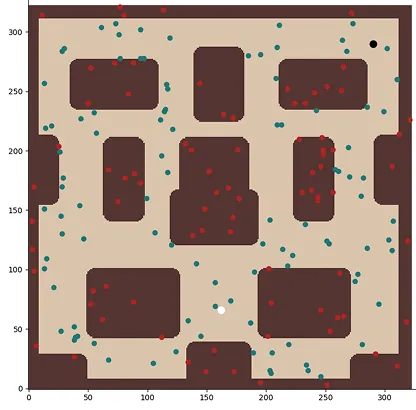
Sample
Scatter random points through what's left.
- 04
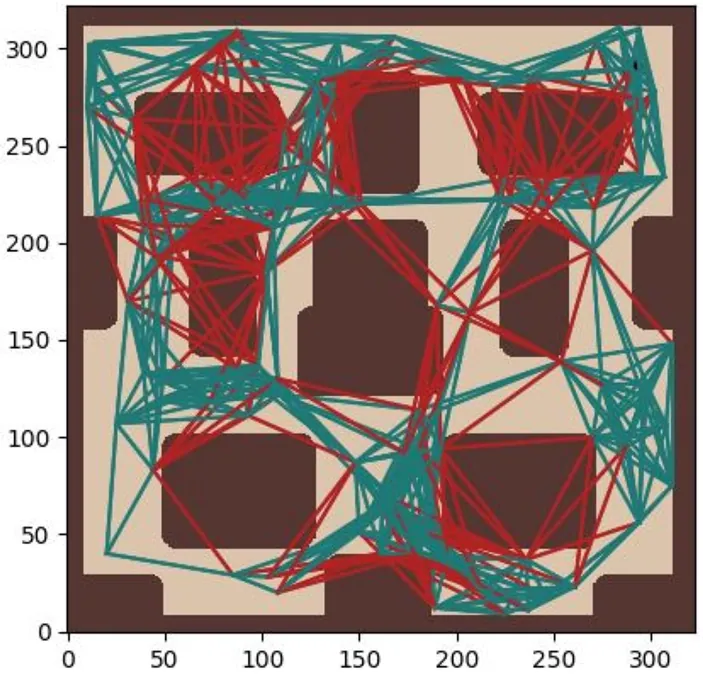
Connect
Join neighbours that can see each other.
- 05
Search
Dijkstra finds the shortest route: 18.05 m, against 22.0 m by hand.
- 06
Push
Torque control, designed to knock the wall down.